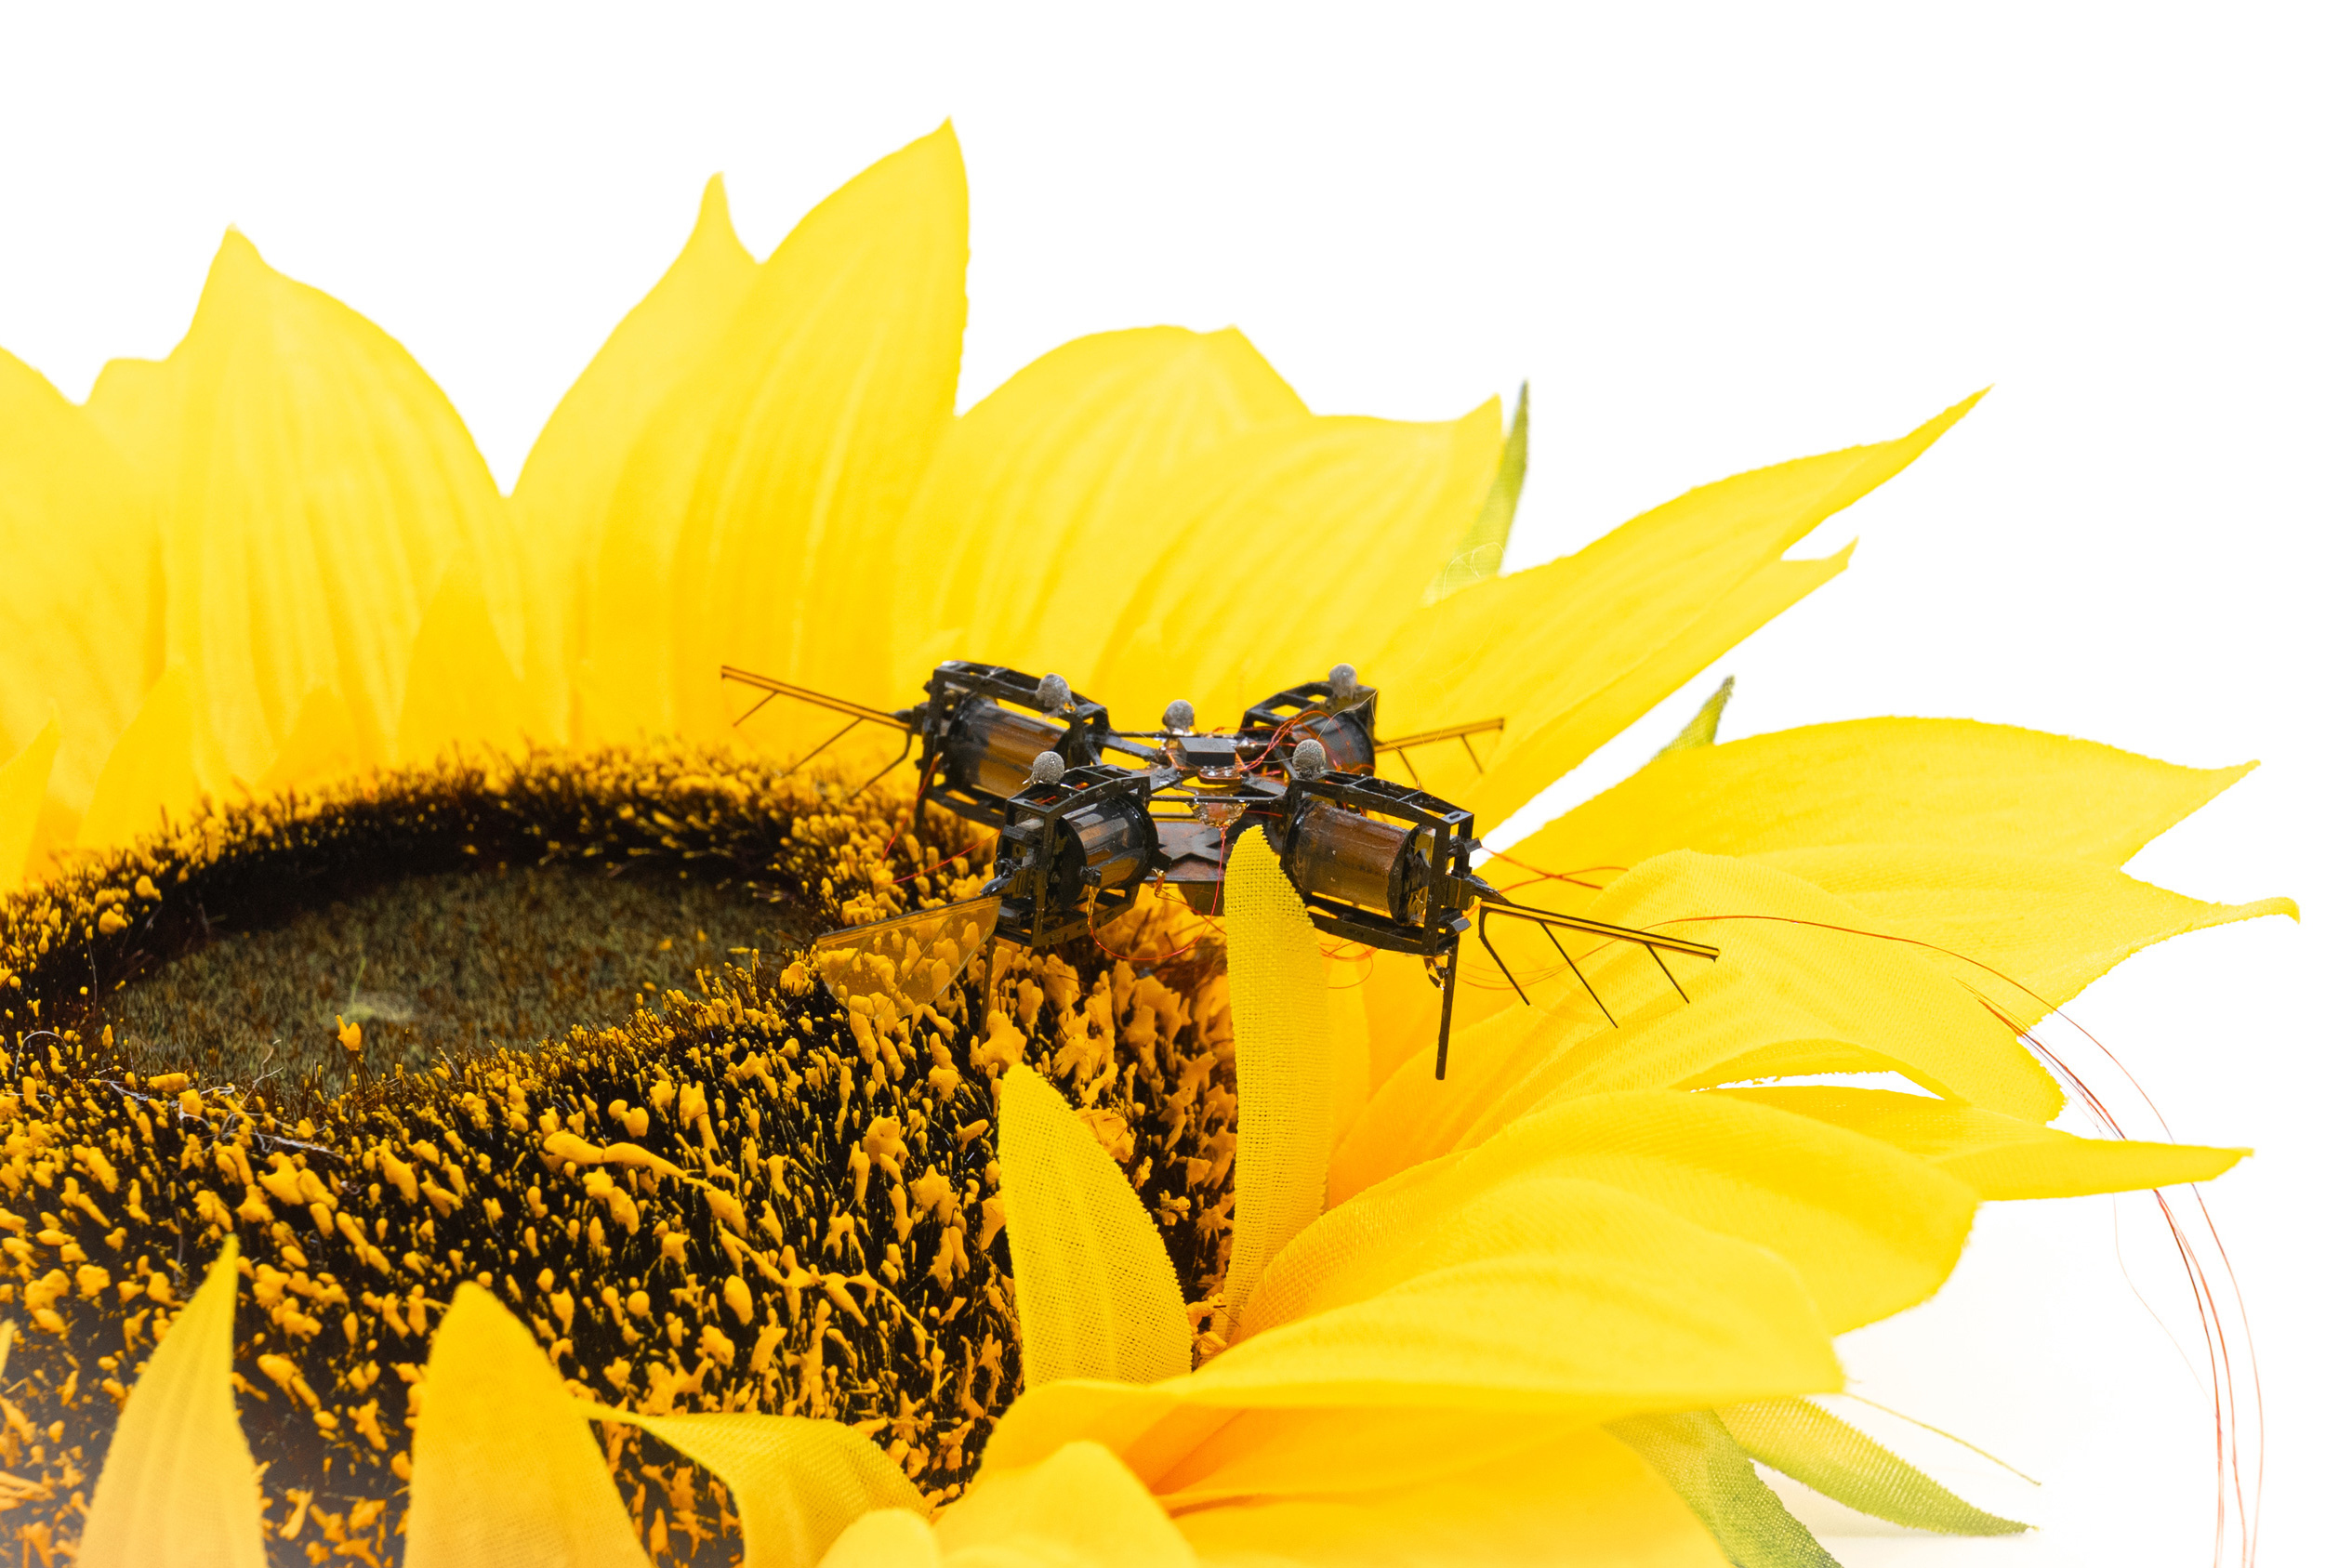
To carry this tiny robotic nearer to real-world functions, the researchers want it to hold the extra weight from electronics for onboard sensing and computation, whereas nonetheless being quick, maneuverable, and sturdy to collisions.
On this analysis, they developed a technique to scale up the substitute muscle mass with out hampering the robotic’s efficiency. They fastidiously tuned the radius and size of the gentle actuators, growing their measurement by 50 % whereas boosting the robotic’s internet carry forces by 46 %.
“It is rather troublesome to scale up the actuators with out inflicting the output energy of the system to go down, which reduces the carry forces. We tuned the geometry of the robotic very exactly so carry proportionally will increase with the extra actuator weight,” Chen explains.
They have been in a position to obtain a lift-to-weight ratio of 1.9, giving the robotic greater than sufficient carry power to hold the onboard electronics package deal they developed, which weighs solely 244 milligrams.
The tiny electronics package deal comprises the sensors, and microcontroller wanted for onboard sensing and computation.
The researchers included an inertial measurement unit to estimate perspective, an optical movement sensor to estimate lateral flight pace and place, and a time-of-flight sensor to measure peak.
However with out the precision of the hooked up movement seize system, the robotic doesn’t know its absolute place, inflicting it to float off beam.
Speedy sensing
To beat this problem, the workforce designed a sensing algorithm to calculate the robotic orientation, angular velocity, and place extraordinarily shortly, simplifying the calculations to scale back the computational price.
They discovered that estimating place repeatedly at a quicker charge yielded increased efficiency than a extra correct, slower estimation.
“We spent quite a lot of time optimizing the choice of the sensors and place estimators so the robotic would have very low drift. Our robotic can now fly with positional accuracy that’s corresponding to flying with offboard cameras,” says Hsiao.
They built-in the sensors and computing parts right into a tiny electronics package deal, which they hooked up to a fiberglass substrate so it wouldn’t be thrown off by vibrations of the robotic.